Mechanical Engineering & Robotics
Robotic manipulation, active perception, mechanical design, sand casting, machining, and rapid prototyping.
ActiveUMI: Robotic Manipulation with Active Perception
Co-authored research on a framework for robotic manipulation with active perception from robot-free human demonstrations. ActiveUMI couples a portable VR teleoperation kit with sensorized controllers, learning the crucial link between visual attention and manipulation.
Policies trained exclusively on ActiveUMI data achieve 70% success rate on bimanual tasks and demonstrate strong generalization, retaining 56% success rate on novel objects and environments.
Co-authors: Qiyuan Zeng, Chengmeng Li, Zhongyi Zhou, Junjie Wen, Guorui Feng, Yichen Zhu, Yi Xu
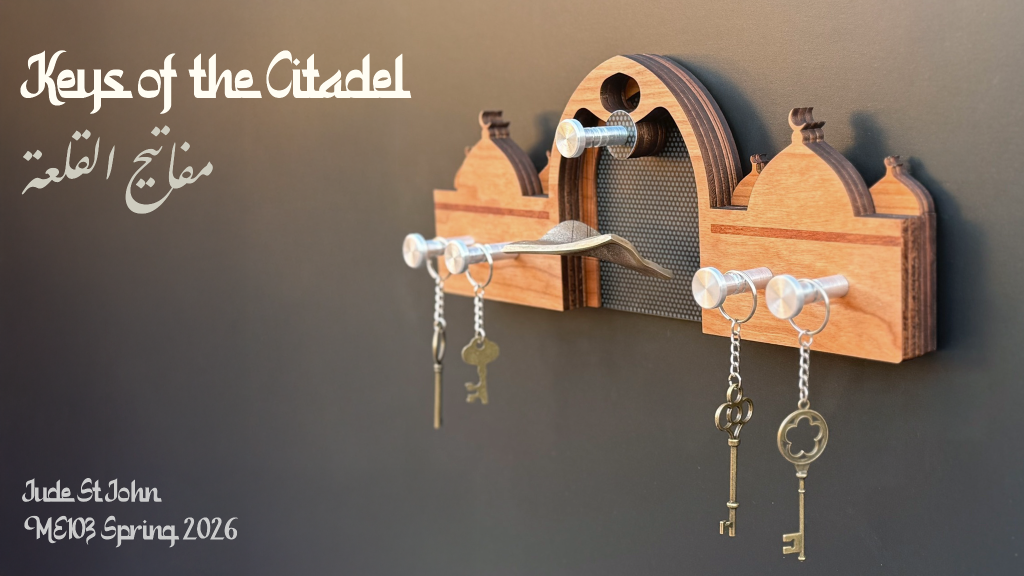
Keys of the Citadel
A wall-mounted key rack combining functional storage with a suspended bronze flying carpet illusion. Inspired by Egyptian architecture with domes, arches, and pillar-like hooks framing the carpet.
Features a sand-cast bronze carpet machined using a 3D-printed fixture on the mill, a laser-cut cherry plycore body with hand-finished dark backing for silent monofilament line suspension, and turned aluminum hooks on the lathe.
Processes: Sand casting, pattern making, milling, turning, laser cutting, wood finishing.
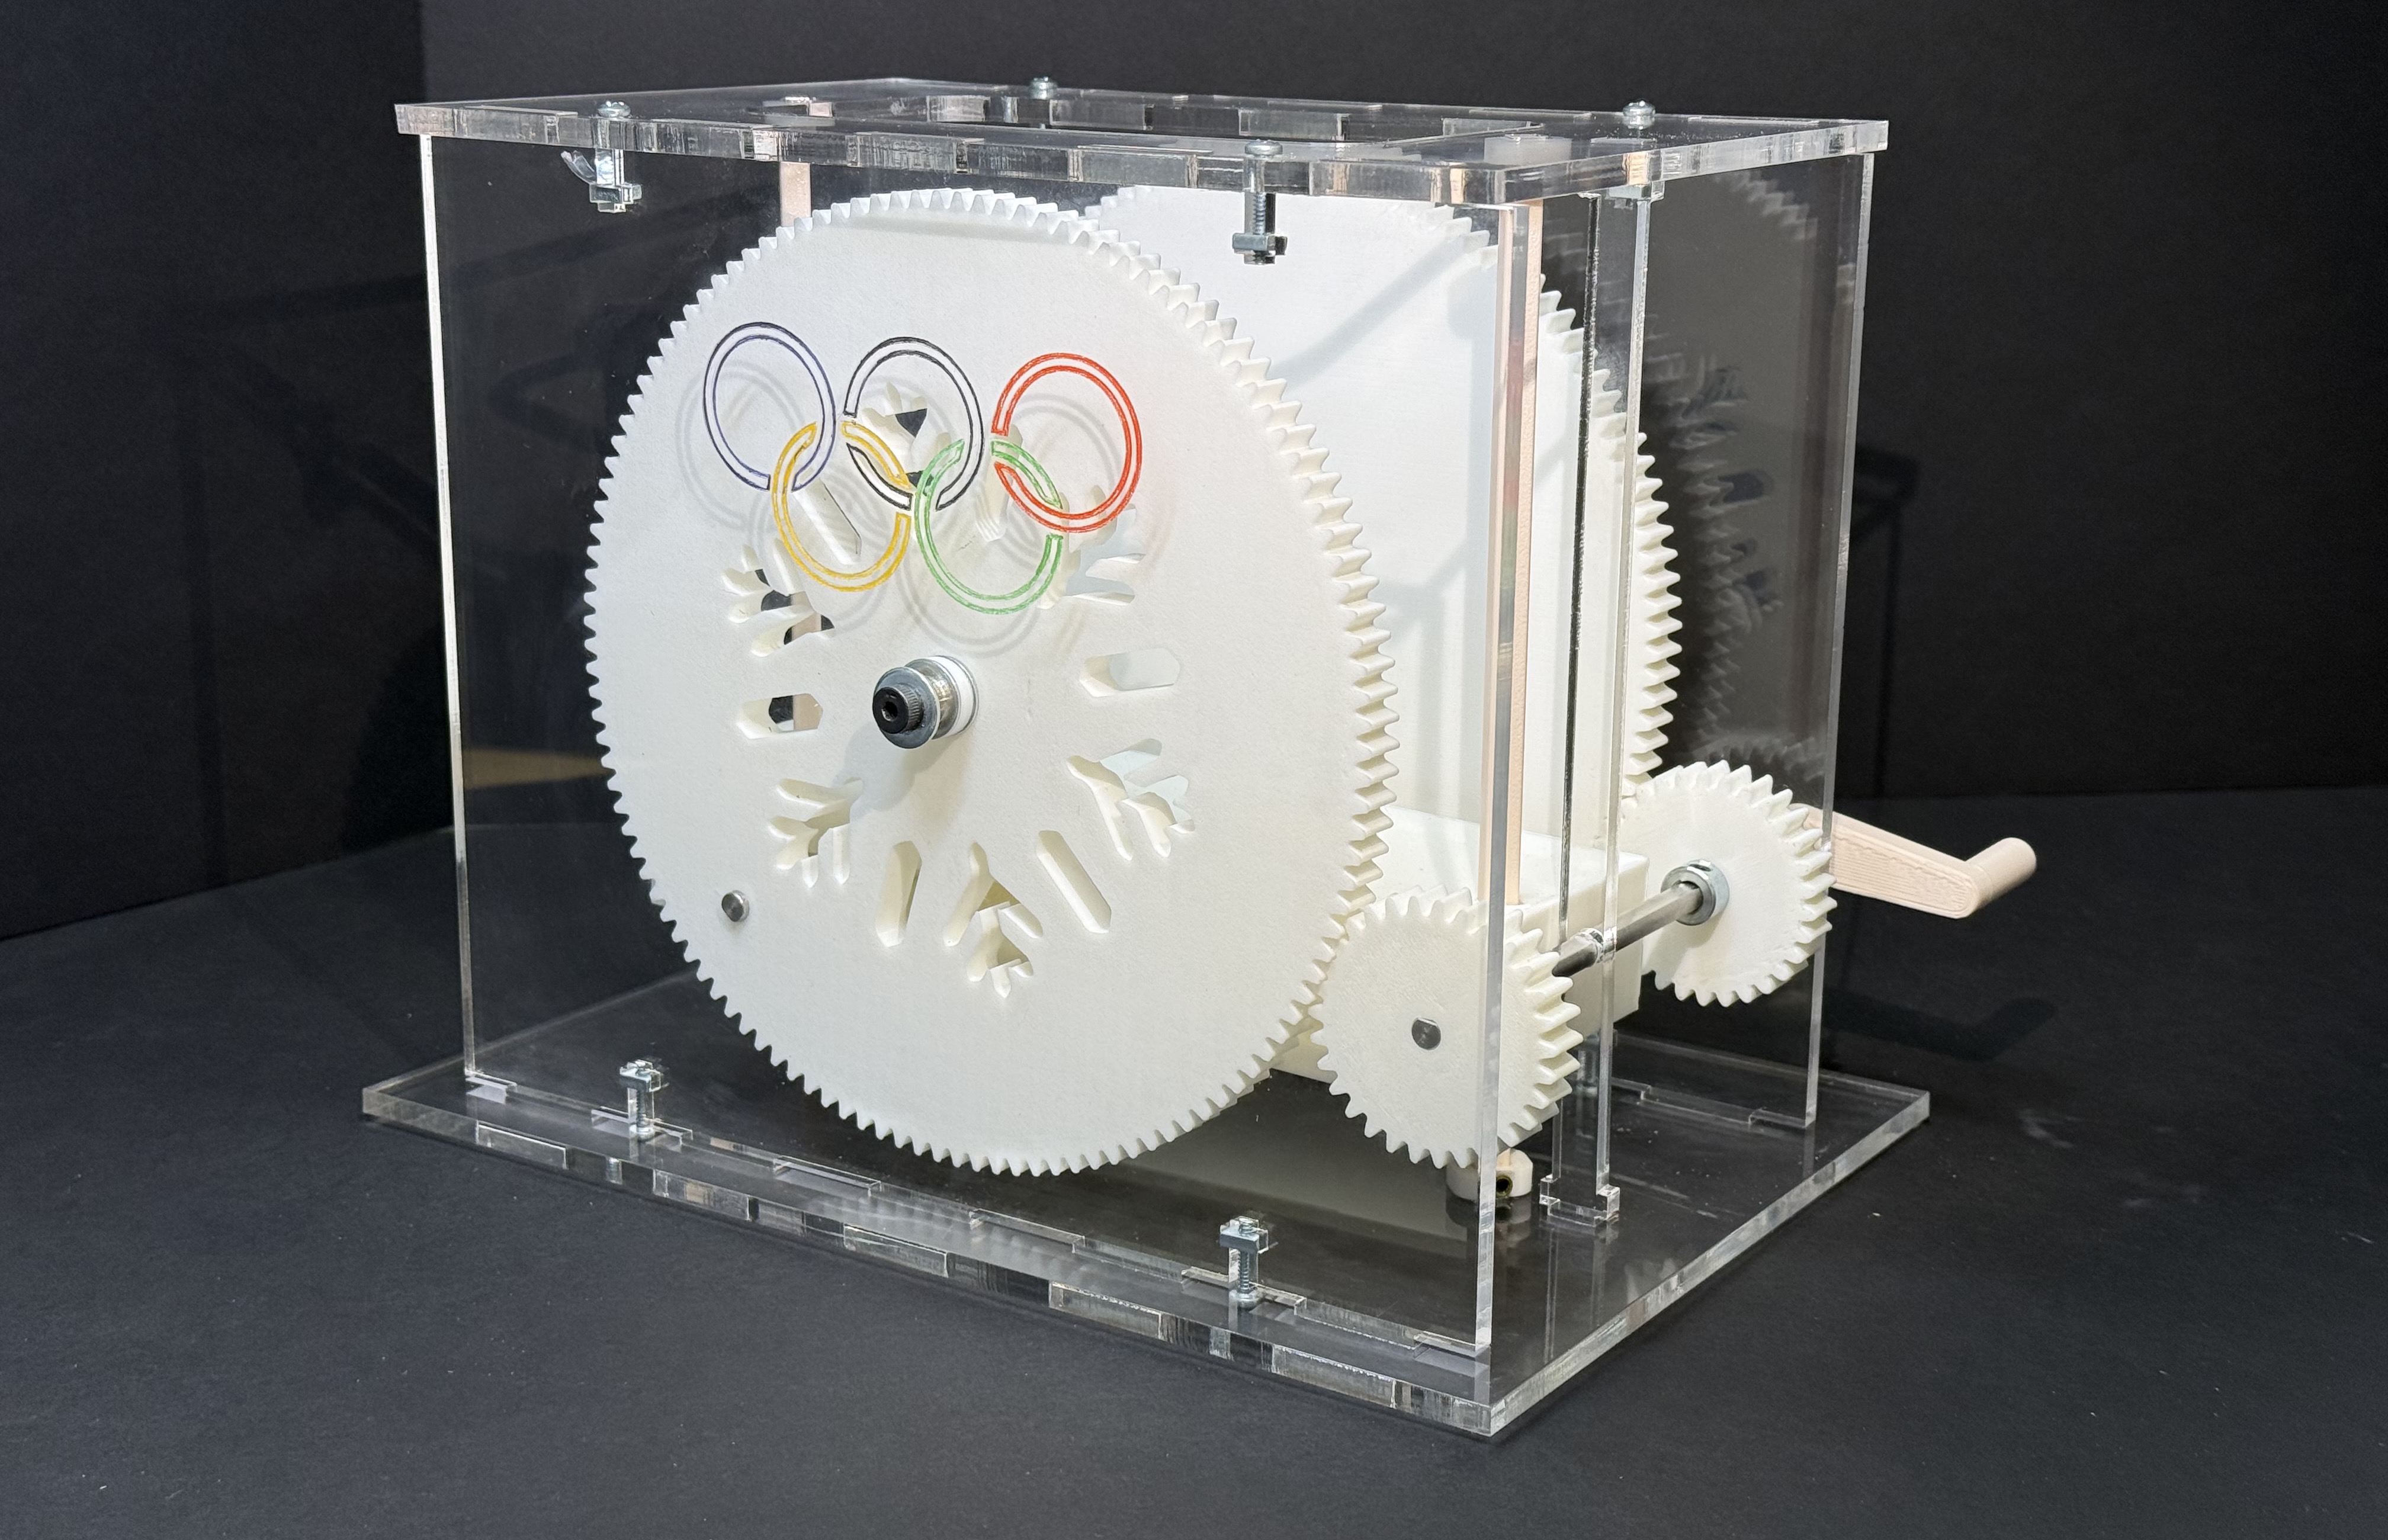
Olympic Podium
Designed and built a mechanism for the Winter Olympics 2026 award podium, converting rotational motion into linear motion to raise athletes using an adapted scotch yoke mechanism.
Project partner: Minoo Jang
Omnicats 1452
Co-captain of FRC Team 1452. Designed, built, and refined competition robots winning regional awards across Canada and Los Angeles.
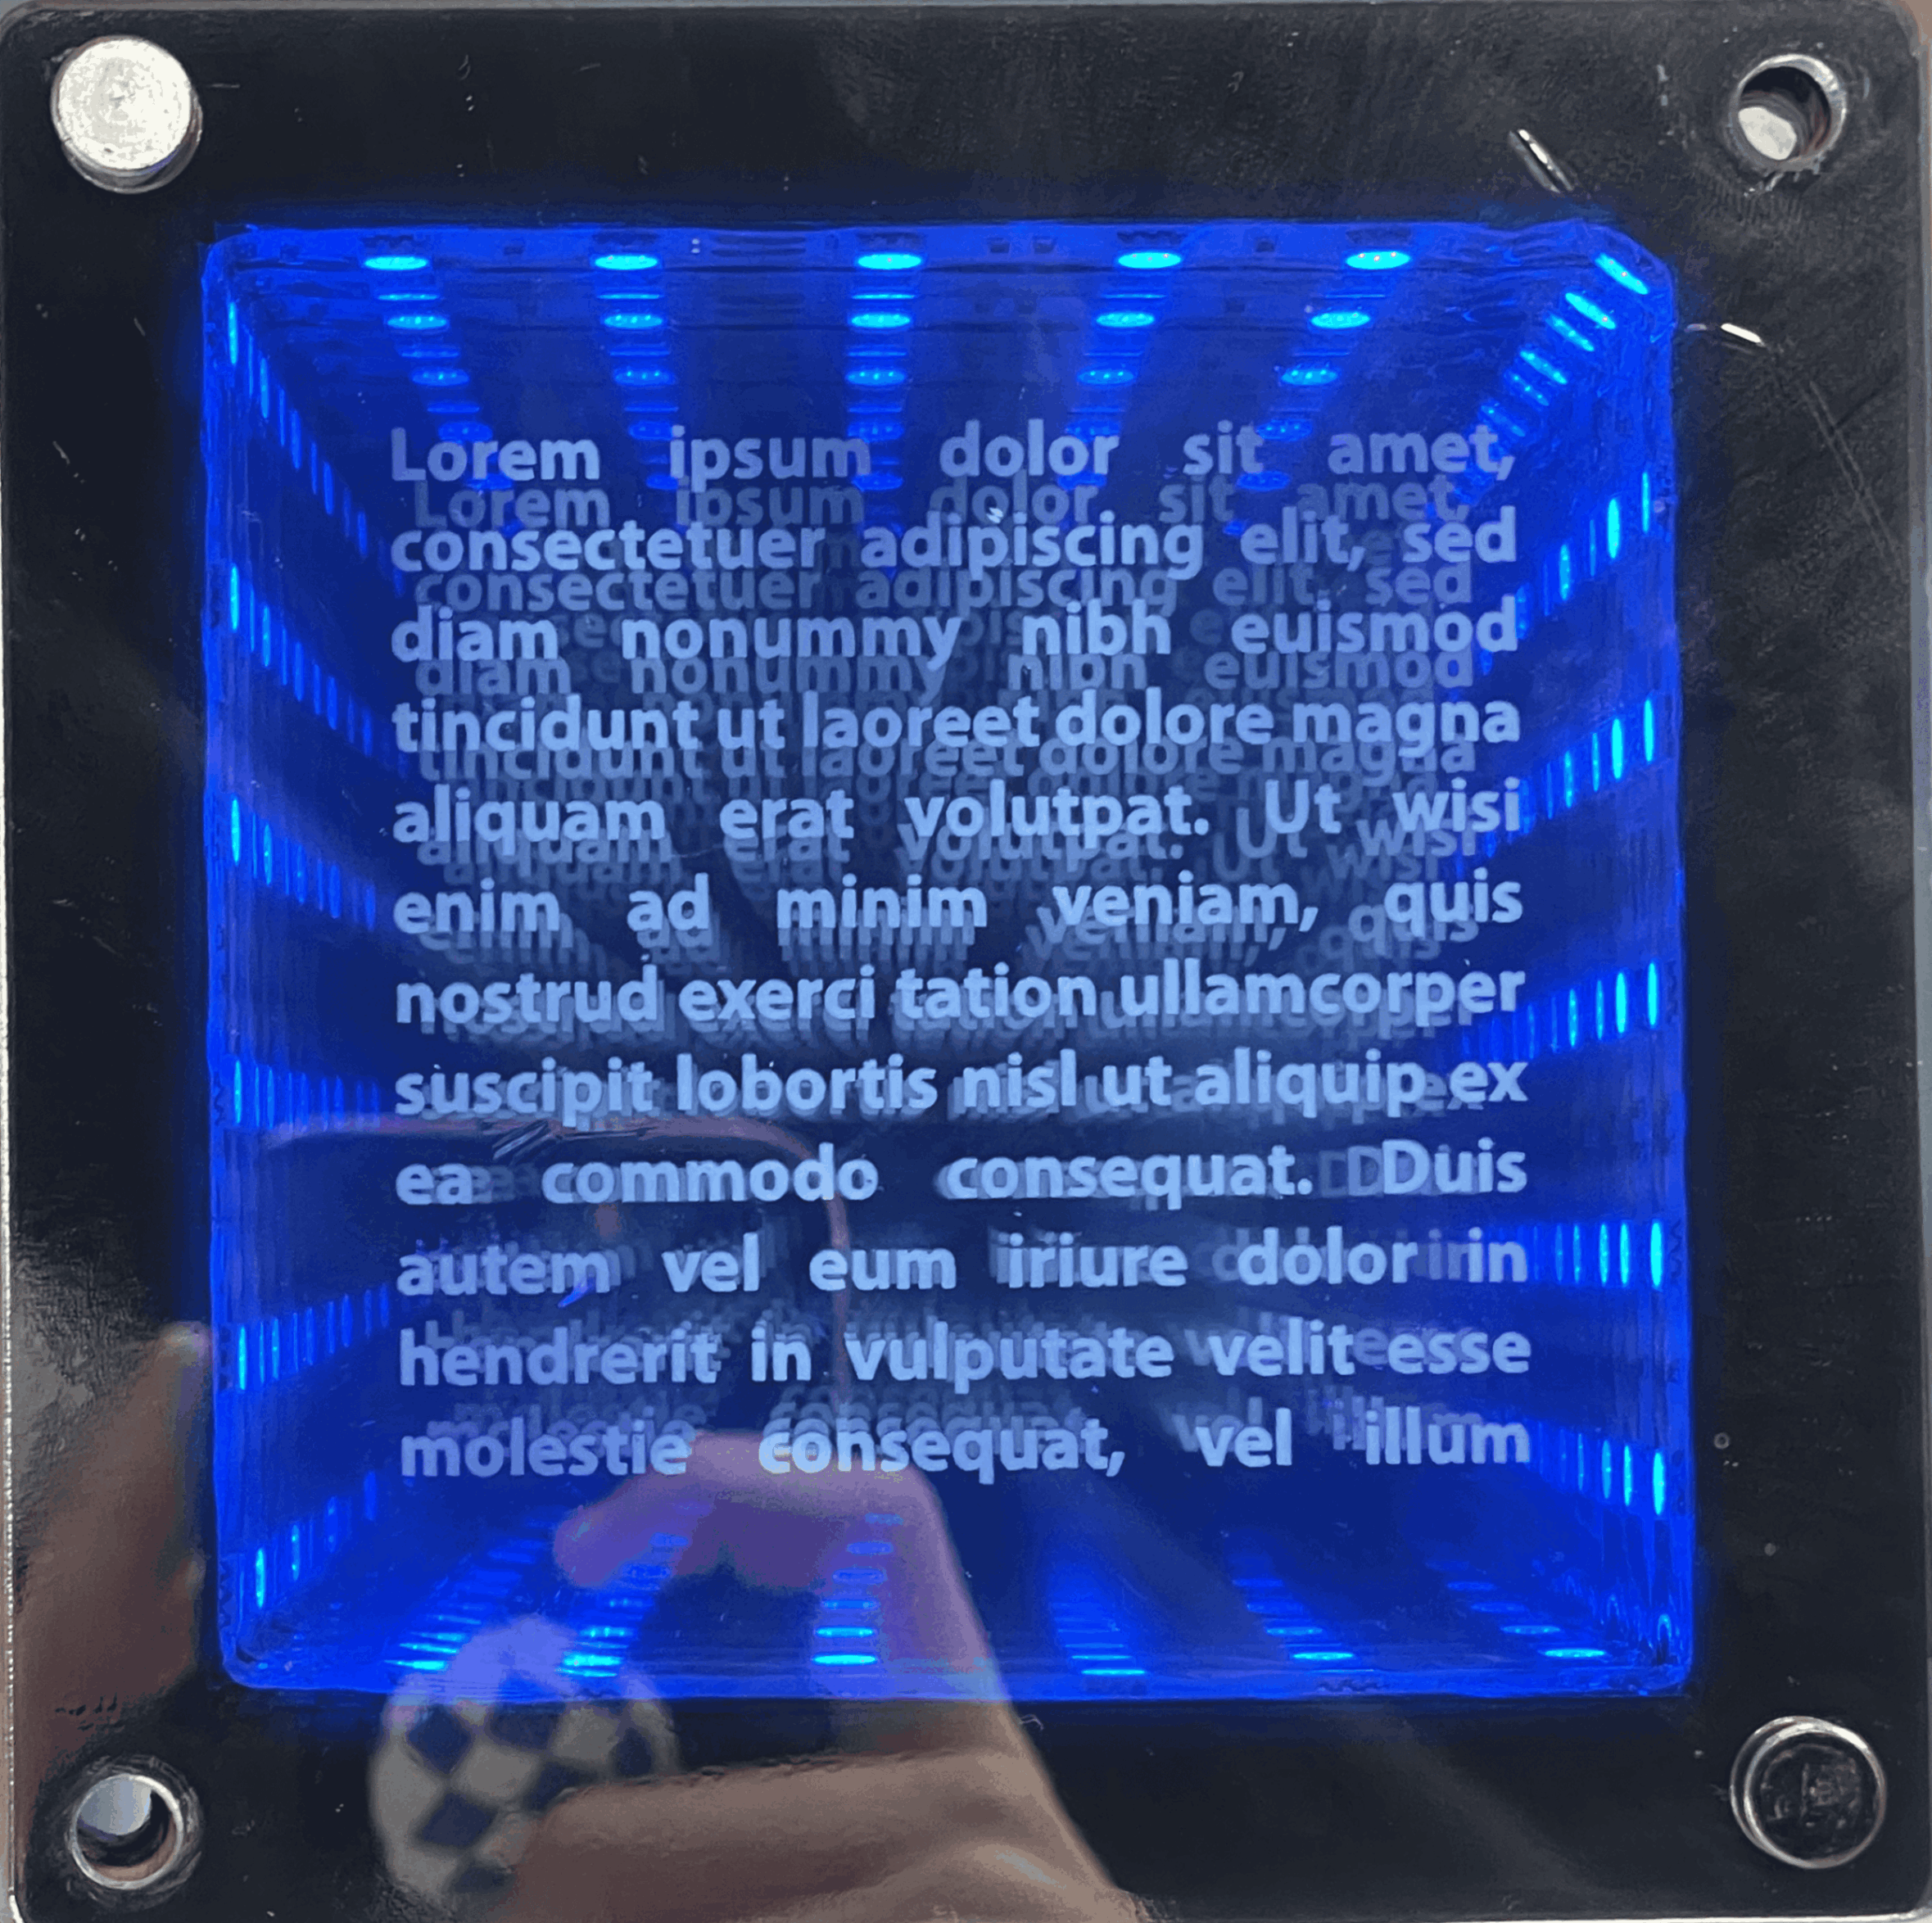
Babel Infinity Mirror
Infinity mirror based on Jorge Luis Borges's Library of Babel, featuring laser-etched text on glass repeated infinitely.
R4 Door Chime Alarm
Soldered circuit and laser-cut housing adapting a toy into a custom door-mounted chime mechanism.
Tensegrity Models
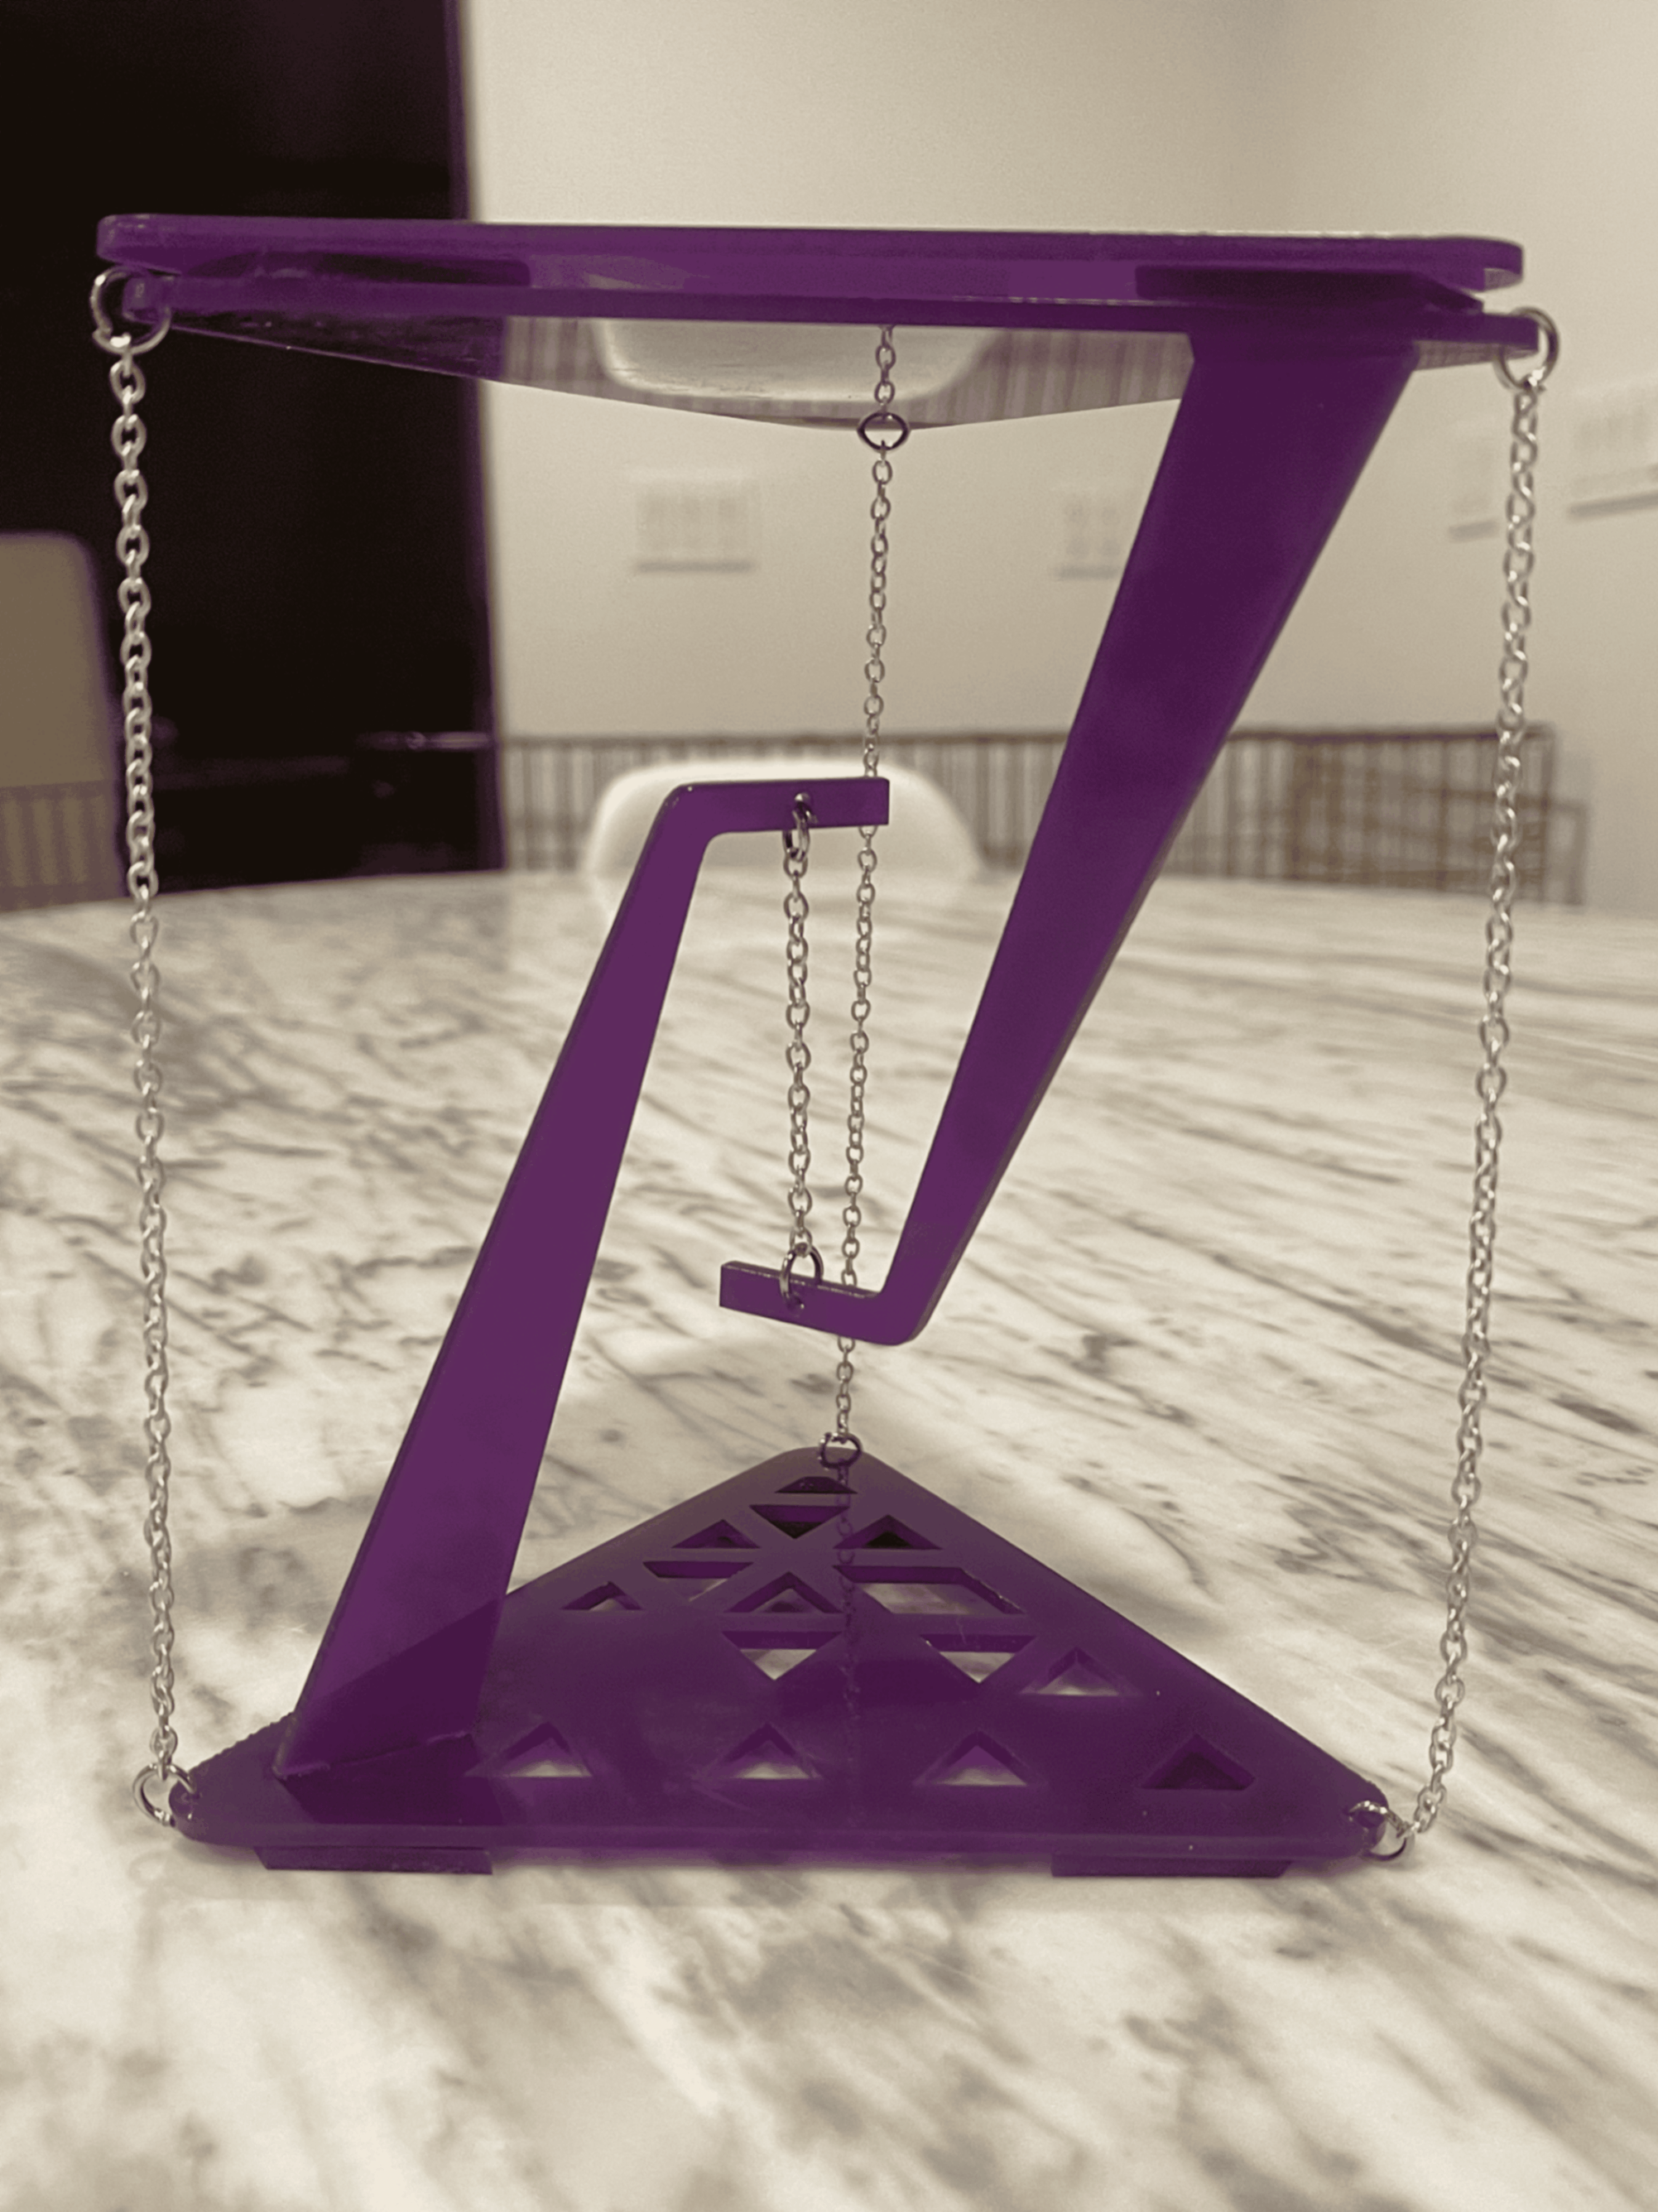
Fabricated tension and compression structures demonstrating floating balance with chains and monofilament.